Project notes
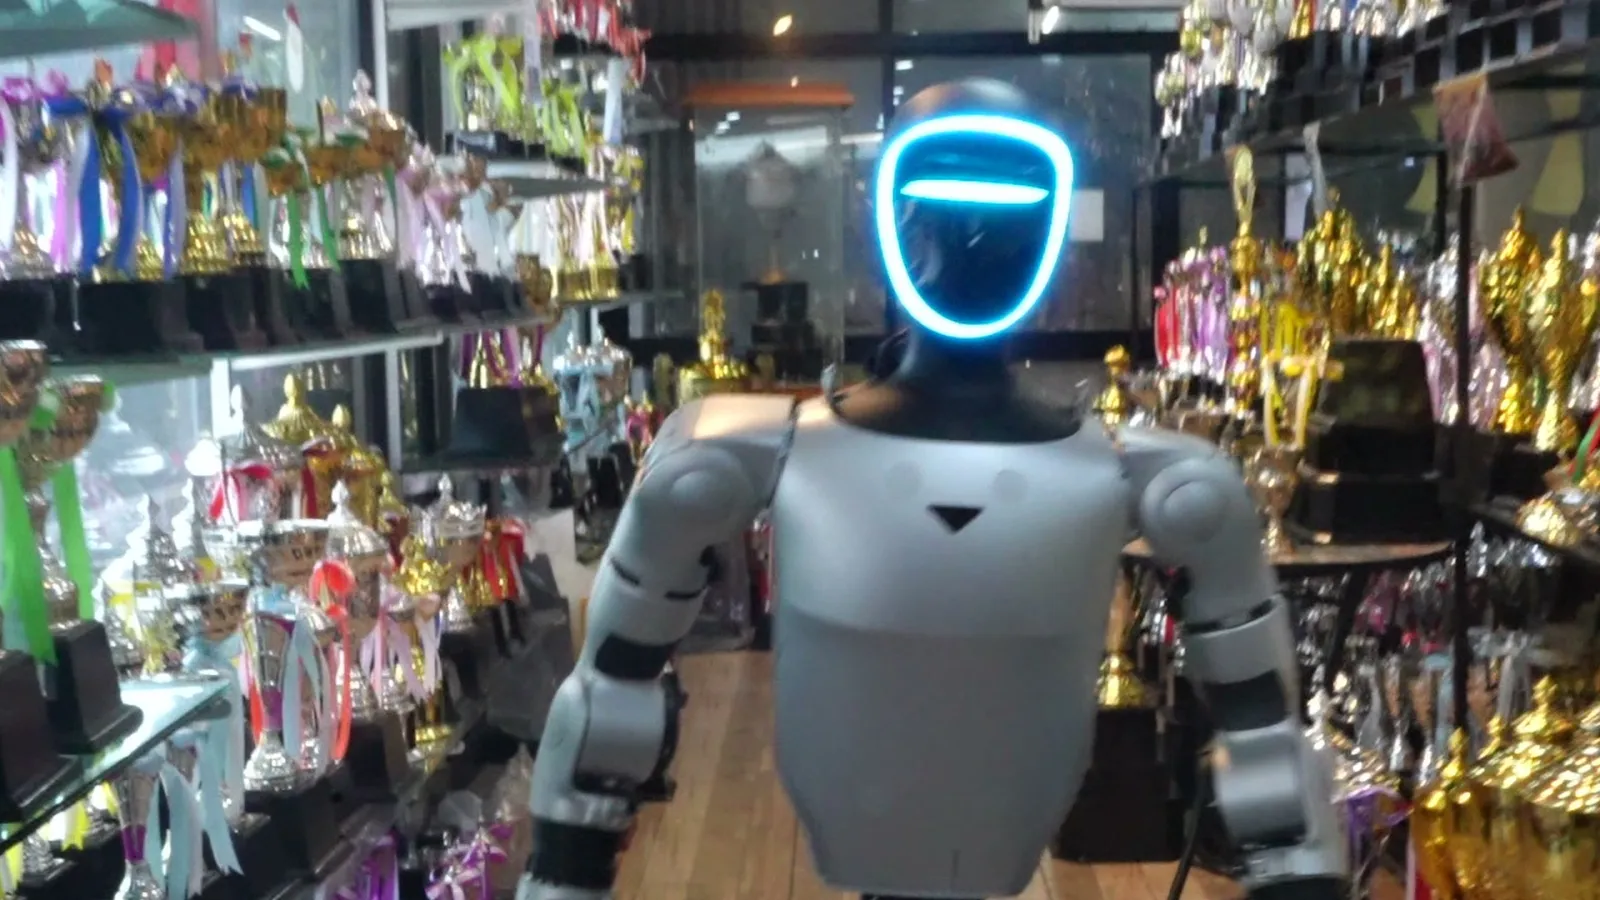
Unitree G1 — Humanoid Robot Workspace
A humanoid robot needs software people can operate at an event.
My part in it
I build the development workspace, show-control app, and bilingual voice assistant.
Simulation, offline controls, and voice interaction in one workspace. Development is ongoing.
The work
The software behind a Unitree G1 EDU humanoid robot that Thaibotic runs at events. A cross-platform dev workspace for macOS, Ubuntu and Windows brings the Python and C++ SDKs, a MuJoCo simulation of the G1 over the same DDS topics as the real robot, and a check that runs a pretrained walking policy in simulation; nothing moves the real robot without two separate confirmations, and walking speeds are clamped for bring-up. On top of it sit the Hub — an offline Thai-language web app that runs the robot at a show from a phone, iPad or laptop through an agent on the robot, with PIN sign-in, one screen in control at a time, walking only while a dead-man button is held, and STOP from any signed-in screen — and a Thai/English voice assistant on the robot's own microphones and speaker that answers through speech-to-text, an LLM and text-to-speech, plus an event mode with arm gestures and announcements. Toolchains for reinforcement learning, ROS 2 mapping and navigation, and LeRobot are set up in the same workspace.
How it evolved
Events — business event kit
NowNov 2026
Added scripts for each kind of business event to the voice assistant and event mode.
Safety — STOP and dead-man hardening
Nov 2026
Made a STOP hold until the dead-man is released, and let a remote press, a STOP or a takeover end a command that is still running.
Hub — offline show-control app
Oct 2026
Shipped the Hub screen, an offline Thai-language web app that runs the robot at a show from a phone, iPad or laptop.
Hub — the on-robot agent
Oct 2026
Built the agent the Hub talks to: posture runs checked against the robot, a control lock, PIN sign-in, and live remote, motor-temperature and battery readings.
Events — event mode and the real-robot gate
Oct 2026
Added an event mode with arm gestures and announcements, behind a gate that needs two confirmations before anything moves the real robot.
Voice — a Thai/English assistant on the robot
Oct 2026
Built a voice assistant on the robot's own microphones and speaker: speech-to-text, an LLM and text-to-speech, answering one sentence at a time.
Cross-platform — Ubuntu and Windows with NVIDIA
Sep 2026
Extended the workspace to Ubuntu and Windows with NVIDIA GPUs, and set up the reinforcement-learning, ROS 2 and LeRobot toolchains.
Workspace — Unitree G1 dev setup on macOS
Sep 2026
Set up a dev workspace for the G1 EDU on Apple silicon: the Python SDK, a MuJoCo simulation over DDS and a doctor that checks every tier.